The problem needs the right operation
A bundle-adjustment problem in the BAL format.
Refine camera poses and 3D points for large photogrammetry problems on the GPU.
Refine camera poses and 3D points for large photogrammetry problems on the GPU.
THE PRODUCT, IN PRACTICE
Refine camera poses and 3D points for large photogrammetry problems on the GPU. It is a newer Garmo Solvers module from the October 2026 benchmark campaign, outside the 1.0.2 release. Results are checked against the original input; the measured result below states where it is ahead and where it is not.
A bundle-adjustment problem in the BAL format.
Refine camera poses and 3D points for large photogrammetry problems on the GPU.
An answer detached from its original constraints or input is difficult to rely on.
The suite rechecks the answer against the original input and identifies the applicable result state.
A capability or benchmark result is not a universal promise for a different workload.
Evaluate the selected input, resource budget, complete cost and required certificate against your baseline.
Refine camera poses and 3D points for large photogrammetry problems on the GPU.
Refined cameras and points, with the final reprojection cost of the original problem reported.
Run it as garmo nlls or through the garmo-mcp server; headless execution fits scripts and automated workflows.
The final cost is evaluated on the original problem, so it compares directly with a baseline solver.
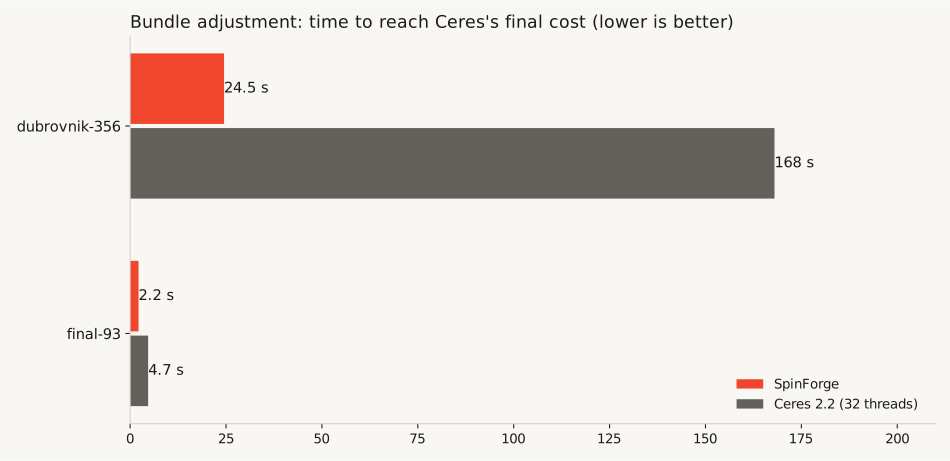
GPU Levenberg-Marquardt with an implicit Schur complement, against Ceres Solver 2.2 with 32 threads on BAL. dubrovnik-356 reaches Ceres's final cost in 24.5 s vs 168 s and ends lower (491,384 vs 493,850); final-93 in 2.2 s vs 4.7 s. Ceres is faster on small problems (under about 2 s), trafalgar-257 and venice-52.
Source: Garmo Labs benchmark campaign, October 2026. Results apply to the stated inputs, hardware and conditions; they are not universal competitor rankings.
See the measured result and chartsA customer has a supported model and wants an accepted result without adopting every other module.
Illustrative customer use—not a new benchmark or completed customer deployment.Provide the original input and define the useful outcome.
Run the selected module under its supported resource and interface scope.
Review the returned answer, original-input checks and completion state.
The GPU path is ahead on large problems; Ceres is faster on small problems and on some reported large cases.
No new standalone price is supplied for this product; request a scoped proposal. The platform plans buy qualified workflows and capacity, not a second charge every time a compatible method is selected. Existing bundle inclusions do not expand automatically.
Available through garmo CLI and garmo-mcp, including headless execution. Product-specific inputs, runtime dependencies, budgets and result checks remain explicit.
Bring a task, an accepted outcome and the environment in which the product needs to work.
Select the capability you need directly or include its compatible role in a qualified platform workflow. Production scope identifies release, environment, capacity and support; a product count is not an entitlement.
Explore monthly plans See the system connectionsUse the software directly or ask us to scope the implementation.
One capability. A connected workflow.
A team to put it into practice.